EffiRLD 高效無人機影像水稻倒伏辨識模型
EffiRLD: High-Efficiency UAV Rice Lodging Recognition Model
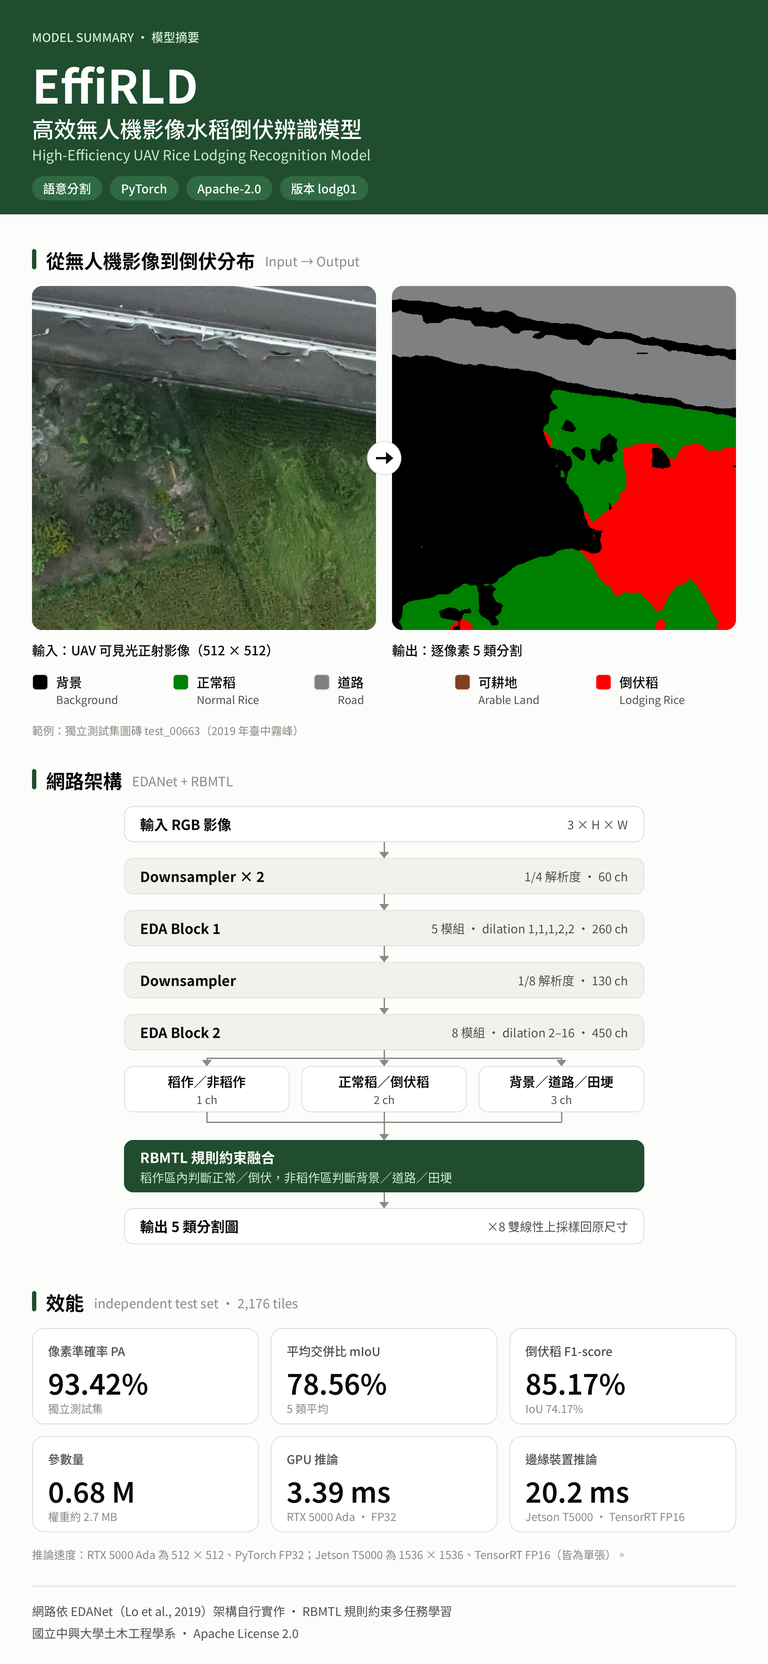
本模型源自EDANet(Efficient Dense Modules of Asymmetric Convolution)改良,並使用PyTorch架構撰寫,針對無人機可見光(RGB)正射影像進行逐像素的水稻倒伏辨識。
模型特色
- 輕量化:僅 683,622 個參數(約 0.68 M),模型權重約 2.7 MB。
- 規則約束多任務學習(RBMTL, Rule-Based Multi-Task Learning):獨立的「稻作/非稻作」分支以機率閘控兩組細分類——稻作區內判斷正常稻或倒伏稻,非稻作區內判斷背景、道路或田埂——從架構上避免道路、田埂等非稻田區域被判為倒伏。
- 可邊緣部署:經 TensorRT 加速後,可在 NVIDIA Jetson 邊緣裝置上即時推論。
輸入與輸出
- 輸入:RGB 三通道影像,邊長為 8 的倍數(訓練圖磚 512×512);大幅正射影像以滑動視窗切塊推論。
- 前處理:像素值除以 255 後,以 mean = std = 0.5 正規化至 -1 到 1。
- 輸出:逐像素類別圖,0 背景、1 正常稻、2 道路、3 田埂、4 倒伏稻。
效能(獨立測試集,2,176 張 512×512 圖磚)
- 像素準確率(PA):93.42%
- 平均交併比(mIoU):78.56%
- 倒伏稻 F1/IoU:85.17%/74.17%
- 正常稻 F1/IoU:96.77%/93.74%
- 推論速度(512×512,FP32,batch 1):NVIDIA RTX 5000 Ada 每張 3.39 ms(約 295 FPS);AMD Threadripper 9960X CPU 每張 37.9 ms(約 26 FPS)
- 邊緣裝置(1536×1536,batch 1):NVIDIA Jetson T5000 以 TensorRT FP16 每張約 20.2 ms(約 49 FPS)
快速使用
- 安裝相依套件:pip install torch numpy Pillow
- 驗證權重與模型定義:python selftest.py
- 單張影像或整個資料夾推論:python predict.py --input 影像或資料夾路徑 --output out --overlay
- 大幅正射影像(滑動視窗):python predict.py --input ortho.tif --output out --tile 512 --overlap 64
- 也可使用套件內的 Dockerfile、env/environment.yml(conda)或 env/apptainer.def(Apptainer)建立環境(含 NVIDIA GPU 版)
- 完整說明請見套件內的 README.zh-TW.md(繁體中文)或 README.md(英文)
適用範圍與限制
- 訓練資料為 2019 年 5 月臺中霧峰地區單一期作之可見光正射影像;應用於其他地區、季別、品種、飛行高度或感測器前,建議先以少量在地標註資料驗證。
- 道路與田埂等細長地物之辨識較弱(測試集 IoU 67.0%、68.8%)。
- 模型輸出為輔助判讀資訊,災損認定仍應由勘災人員複核。
English Overview
EffiRLD is a lightweight semantic segmentation model improved from EDANet (Efficient Dense Modules of Asymmetric Convolution) and implemented in PyTorch. It performs pixel-wise rice lodging recognition on UAV visible-light (RGB) orthophotos.
Key Features
- Lightweight: only 683,622 parameters (about 0.68 M); the model weights take about 2.7 MB.
- Rule-based multi-task learning (RBMTL): a dedicated paddy / non-paddy branch gates two fine-grained heads with its probability. Inside paddy areas the model chooses between normal and lodged rice; outside them it chooses among background, road and ridge. By design, roads, ridges and other non-paddy areas cannot be labeled as lodging.
- Edge-ready: accelerated with TensorRT, it runs in real time on NVIDIA Jetson edge devices.
Input and Output
- Input: 3-channel RGB image whose sides are multiples of 8 (training tiles are 512×512); large orthophotos are processed with a sliding window.
- Preprocessing: pixel values are divided by 255 and normalized with mean = std = 0.5 to the range -1 to 1.
- Output: per-pixel class map with 0 background, 1 normal rice, 2 road, 3 ridge, 4 lodged rice.
Performance (independent test set, 2,176 tiles of 512×512)
- Pixel accuracy (PA): 93.42%
- Mean intersection over union (mIoU): 78.56%
- Lodged rice F1 / IoU: 85.17% / 74.17%
- Normal rice F1 / IoU: 96.77% / 93.74%
- Inference speed (512×512, FP32, batch 1): 3.39 ms per tile on an NVIDIA RTX 5000 Ada (about 295 FPS); 37.9 ms per tile on an AMD Threadripper 9960X CPU (about 26 FPS)
- Edge device (1536×1536, batch 1): about 20.2 ms per image on an NVIDIA Jetson T5000 with TensorRT FP16 (about 49 FPS)
Quick Start
- Install dependencies: pip install torch numpy Pillow
- Verify the weights and model definition: python selftest.py
- Predict a single image or a whole folder: python predict.py --input path/to/images --output out --overlay
- Large orthophotos (sliding window): python predict.py --input ortho.tif --output out --tile 512 --overlap 64
- Docker, conda and Apptainer environments (including NVIDIA GPU builds): Dockerfile, env/environment.yml and env/apptainer.def in the package
- See README.md (English) or README.zh-TW.md (Traditional Chinese) in the package for full instructions
Scope and Limitations
- The training data are visible-light orthophotos of a single rice crop season in Wufeng District, Taichung, Taiwan, captured in May 2019. Before applying the model to other regions, seasons, cultivars, flight altitudes or sensors, validate it on a small set of locally labeled data.
- Thin, elongated objects such as roads and ridges are recognized less reliably (test IoU 67.0% and 68.8%).
- The model output is decision support only; damage assessments must be reviewed by field inspectors.
資料與資源
基礎工具
-
LICENSE.txtTXT
LICENSE.txt 名稱:授權條款 Apache License 2.0(License) 格式:TXT 授權條款:Apache License...
-
SHA256SUMS.txtTXT
SHA256SUMS.txt 名稱:SHA-256 校驗碼(Checksums) 格式:TXT SHA-256 校驗碼...
-
EffiRLD_lodg01_summary.pngPNG
EffiRLD_lodg01_summary.png 名稱:模型摘要圖(Model summary) 格式:PNG EffiRLD 模型摘要圖...
應用模型
-
EffiRLD_lodg01_OpenPack.zipZIP
EffiRLD_lodg01_OpenPack.zip 名稱:EffiRLD 模型套件(Model package) 格式:ZIP EffiRLD...
額外的資訊
| 欄位 | 值 |
|---|---|
| 最後更新 | 10月 23, 2026, 15:53 (+0800) |
| 建立 | 9月 29, 2026, 17:13 (+0800) |
推薦AI模型
作物蟲害多光譜預警系統
更新頻率瀏覽次數
下載次數
作物蟲害無人機預警系統
更新頻率瀏覽次數
下載次數
稻穗影像去背模型
更新頻率瀏覽次數
下載次數